

 menu
|
|
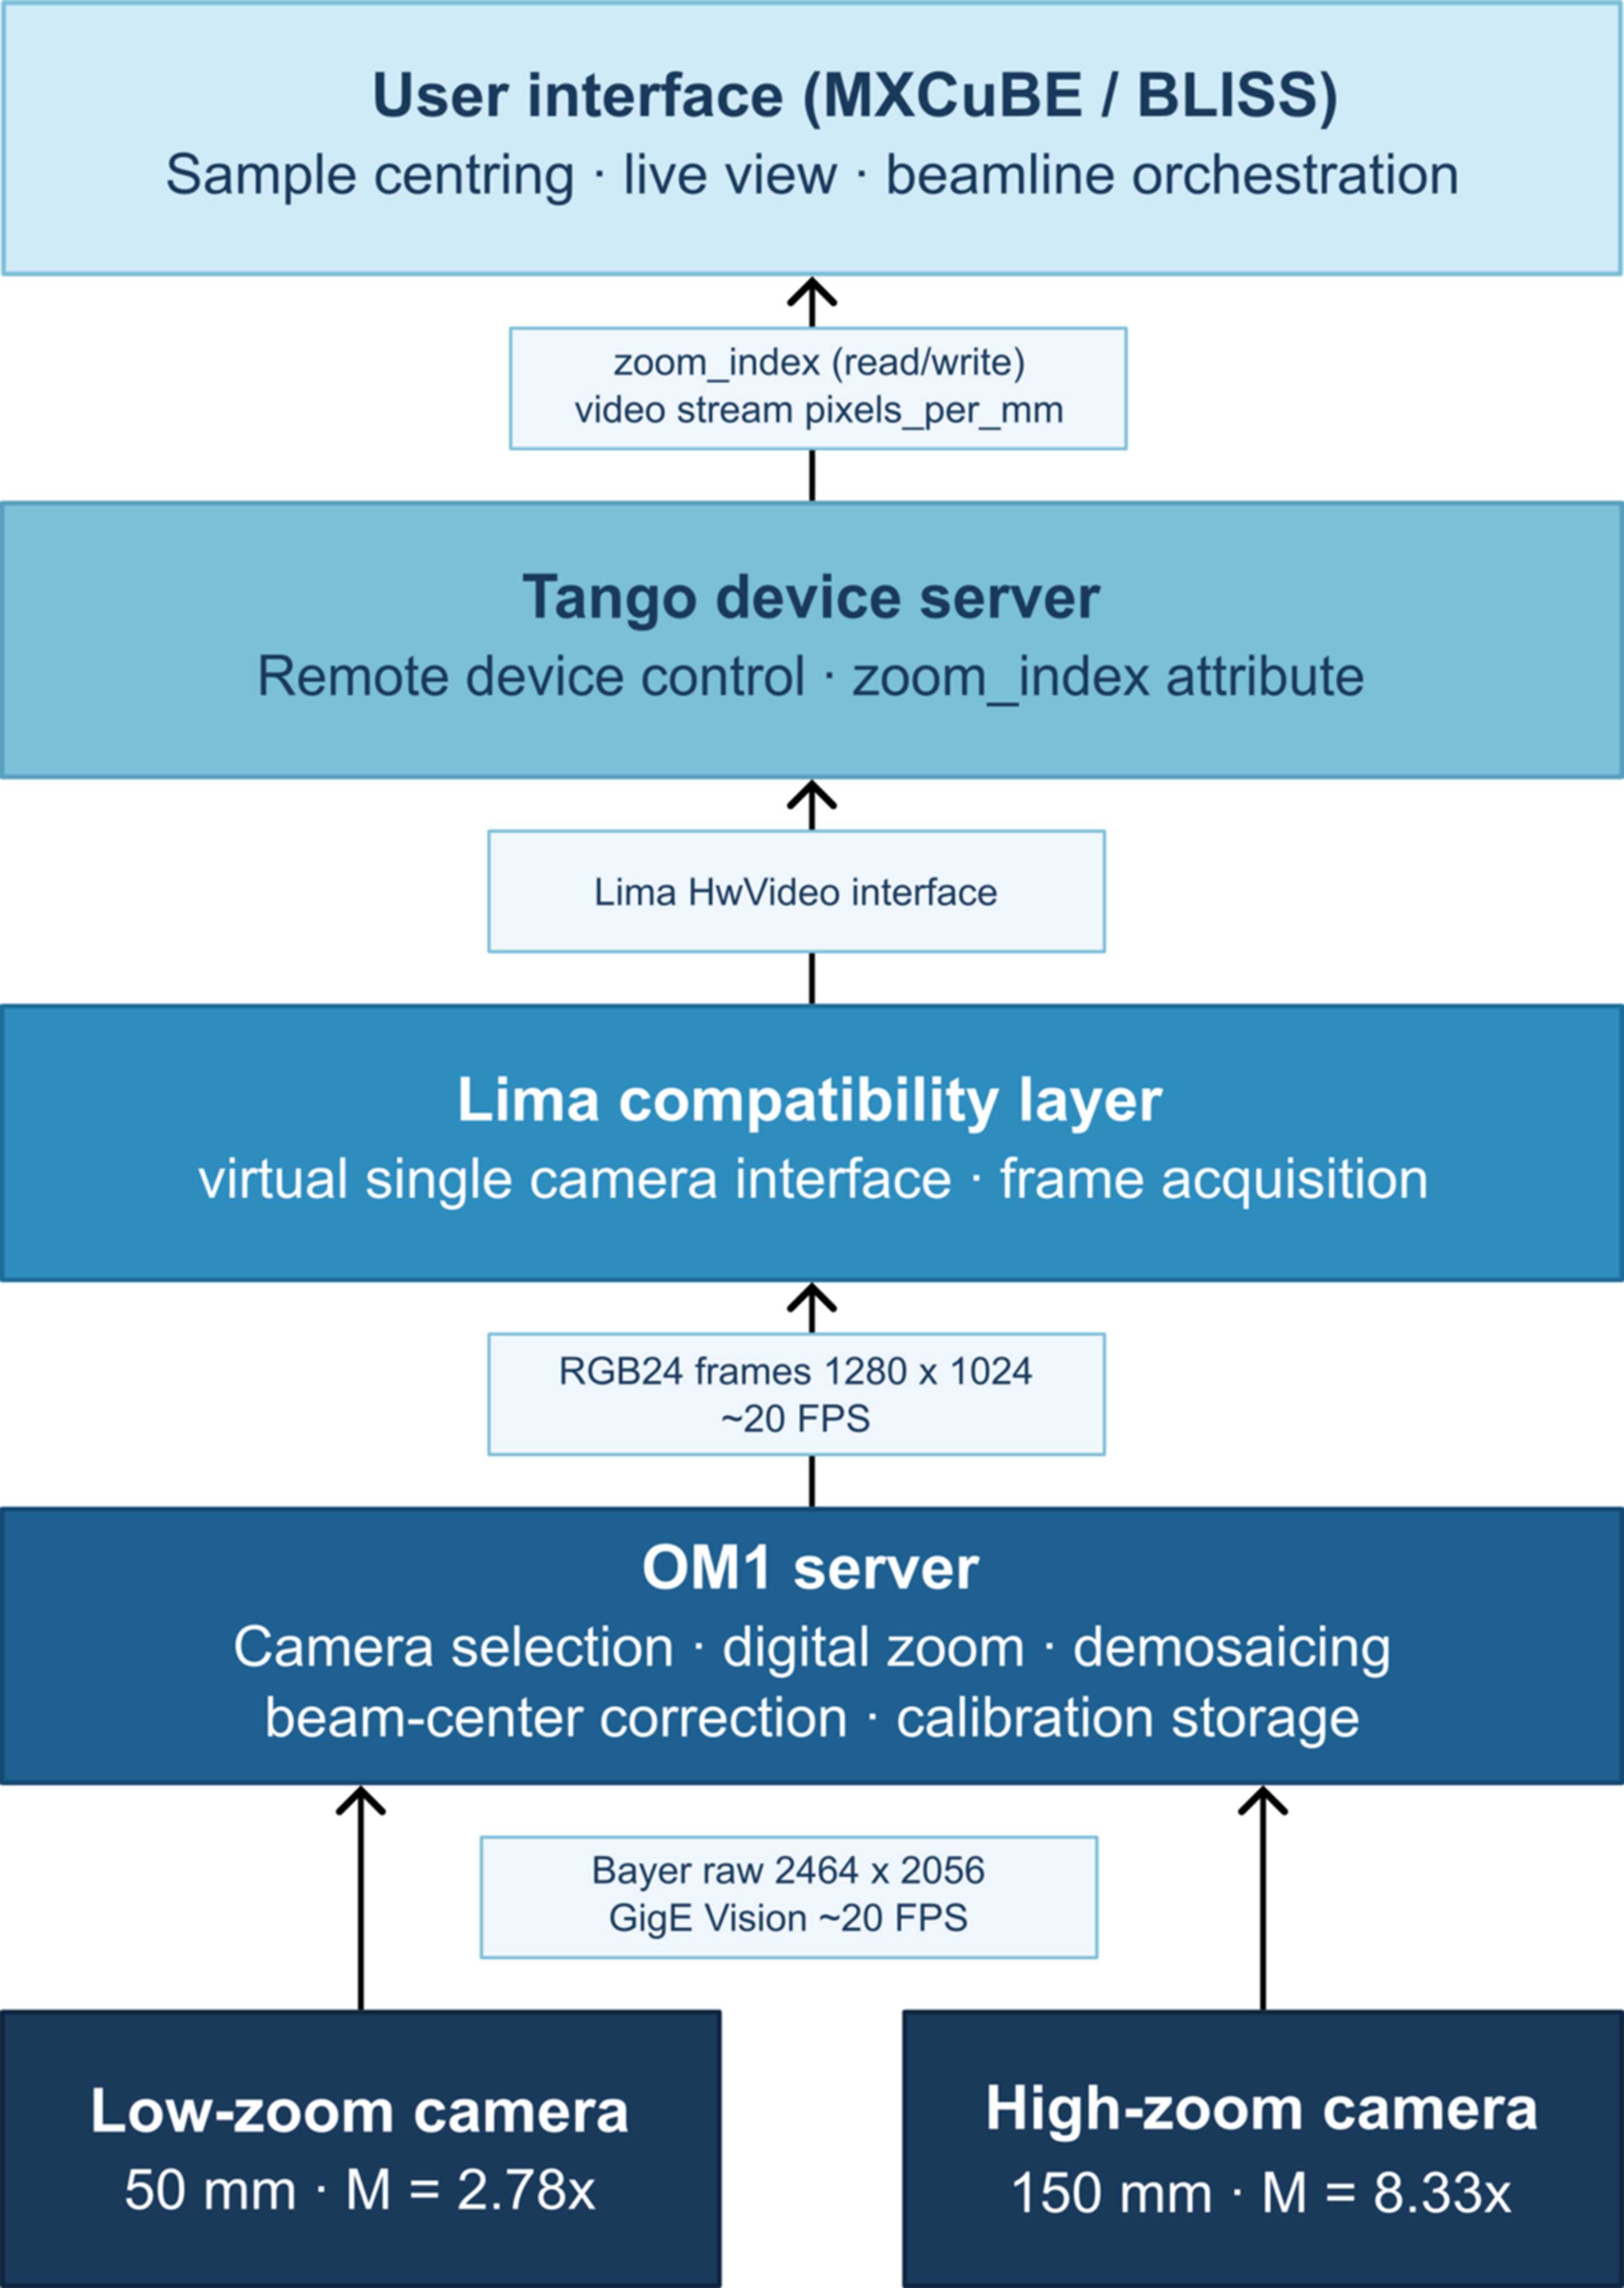
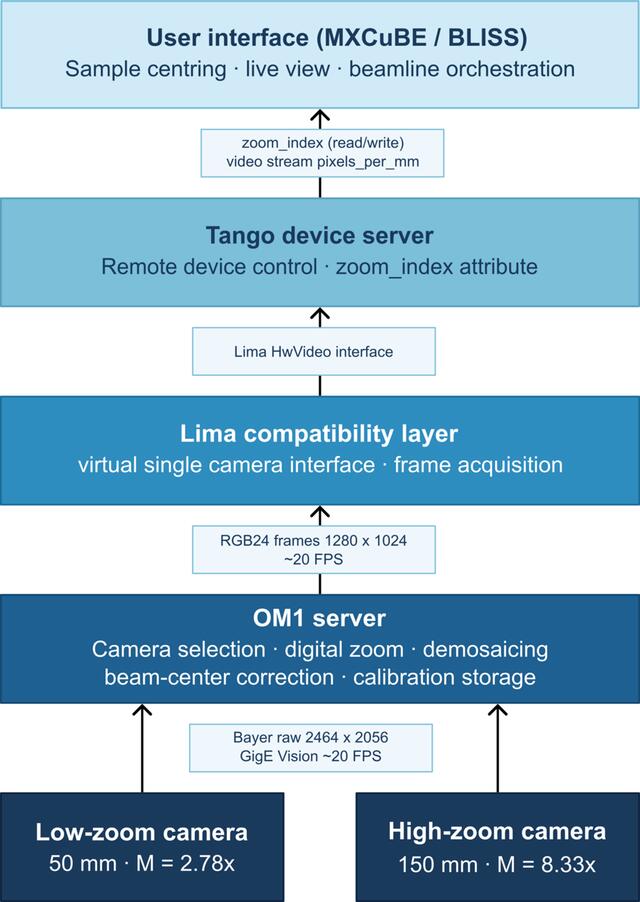
Figure 2
Software architecture of the on-axis dual magnification viewer system. The acquisition pipeline runs from hardware to user across five layers. The two Basler (ref. acA2440-20gc) cameras transmit raw Bayer frames with a resolution of 2464 × 2056 pixels via the GigE Vision interface to the on-axis dual magnification server (OM1 server), which performs demosaicing, beam-centre correction and digital zoom before delivering a fixed-format RGB24 stream (1280 × 1024 pixels, ∼20 FPS) to the LIMA layer. The Tango device server exposes the system as a standard network device, providing remote access to the video stream and the zoom index attribute. At the user level, MXCUBE is the primary client for routine operation, i.e. controlling zoom, displaying the live video stream and retrieving per-axis pixel-to-millimetre conversion factors for sample-centring calculations, while BLISS provides complementary access to the zoom index for beamline-level scripting. This architecture requires no modification to the upstream software stack, as the dual-camera system is presented to LIMA, Tango and MXCUBE as a single virtual on-axis viewer implementing a standard interface. |
 | JOURNAL OF SYNCHROTRON RADIATION |
ISSN: 1600-5775
 access